/ 01
Drones
Designing, modifying and experimenting with aerial platforms: FPV, autonomous UAVs, long range, payloads, telemetry and embedded systems.
Active
Spartan Systems is an independent engineering and experimental research lab exploring drones, robotics, electronics, AI, cybersecurity, gadgets, aerospace and emerging technologies. We design, build, test and document real systems.
06
Domains
R&D
Active
Open
Source
Our projects span several disciplines. Some experiments stay simple. Others grow into full systems.
Designing, modifying and experimenting with aerial platforms: FPV, autonomous UAVs, long range, payloads, telemetry and embedded systems.
Mobile robots, motor control, sensors, navigation, ROS, autonomous systems and experimental machines.
Microcontrollers, sensors, communications, PCBs, power systems and embedded electronics designed to go from prototype to field.
Computer vision, detection, classification, autonomous systems and applied model experimentation in the physical world.
Security in the broad sense: radio protocols (SDR, sub-GHz, LoRa, BLE, RFID/NFC, GNSS), connected devices and embedded systems, networks — and building electronic gadgets to analyze them, detect trackers and bugs, and test link resilience, in authorized environments.
Space and aerospace experimentation: avionics, telemetry, embedded sensors and systems built for extreme environments.
Projects, experiments, technical breakdowns and build logs.
09 JUL 2026
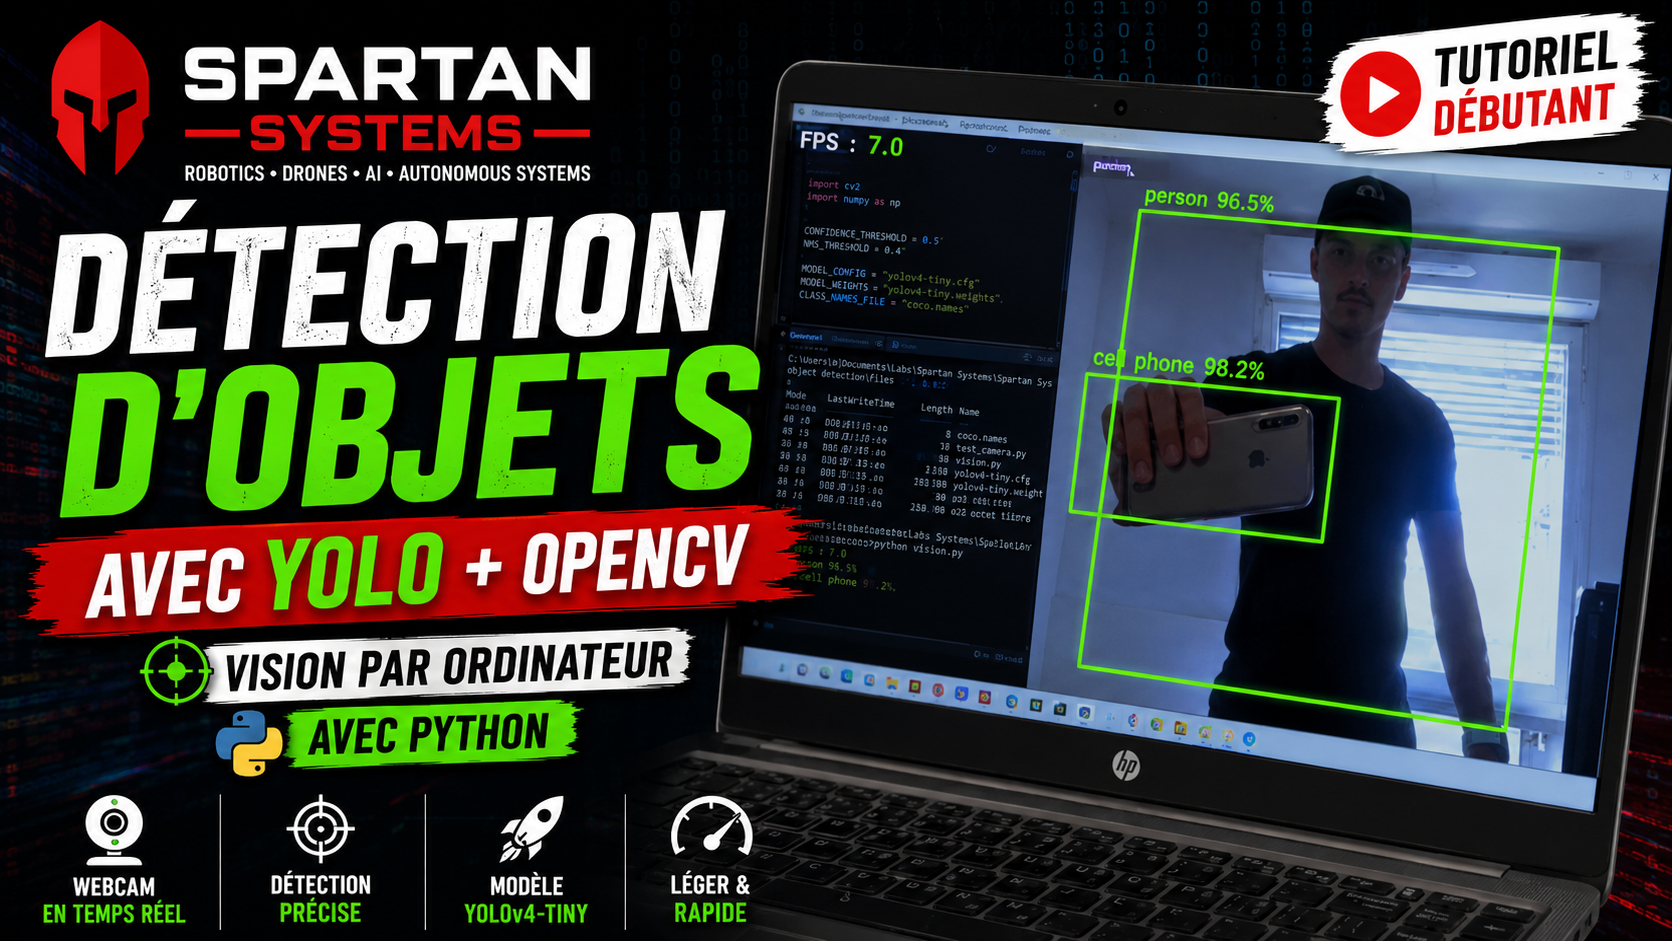
A complete tutorial to build a real-time object detection system using a webcam, Python, OpenCV and YOLOv4-tiny — setup, commented code and video demonstration.
22 JUN 2026
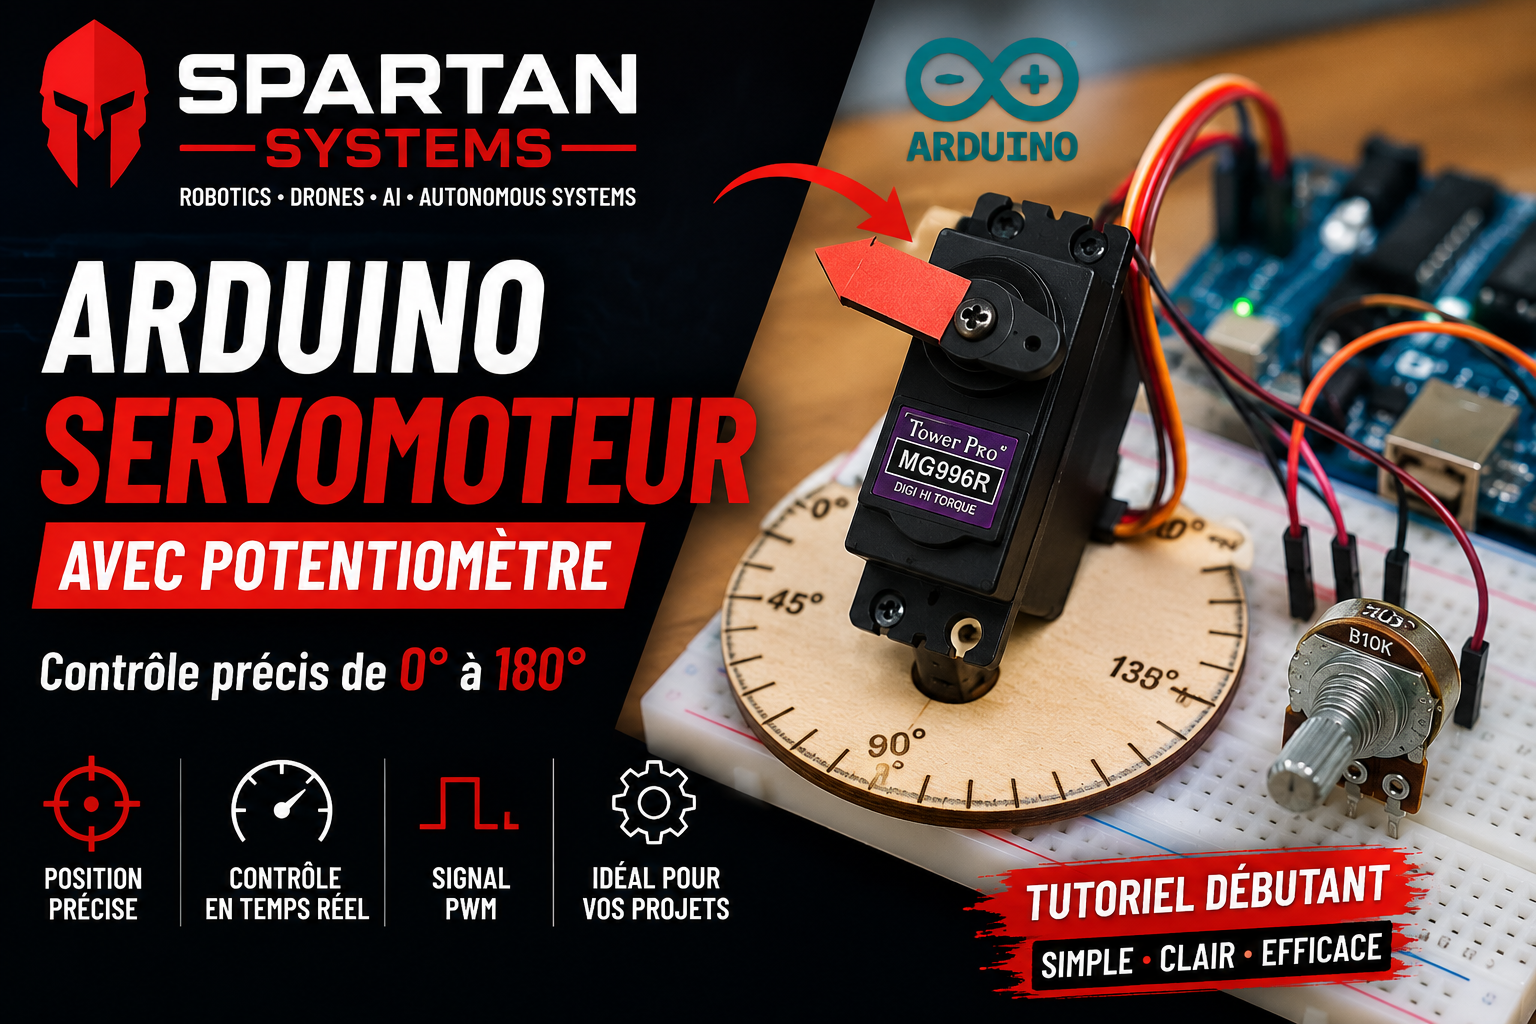
Complete tutorial for driving a MG996R servo motor with an Arduino Uno and a 10 kΩ potentiometer — wiring, PWM signal, code and assembly.
17 JUN 2026
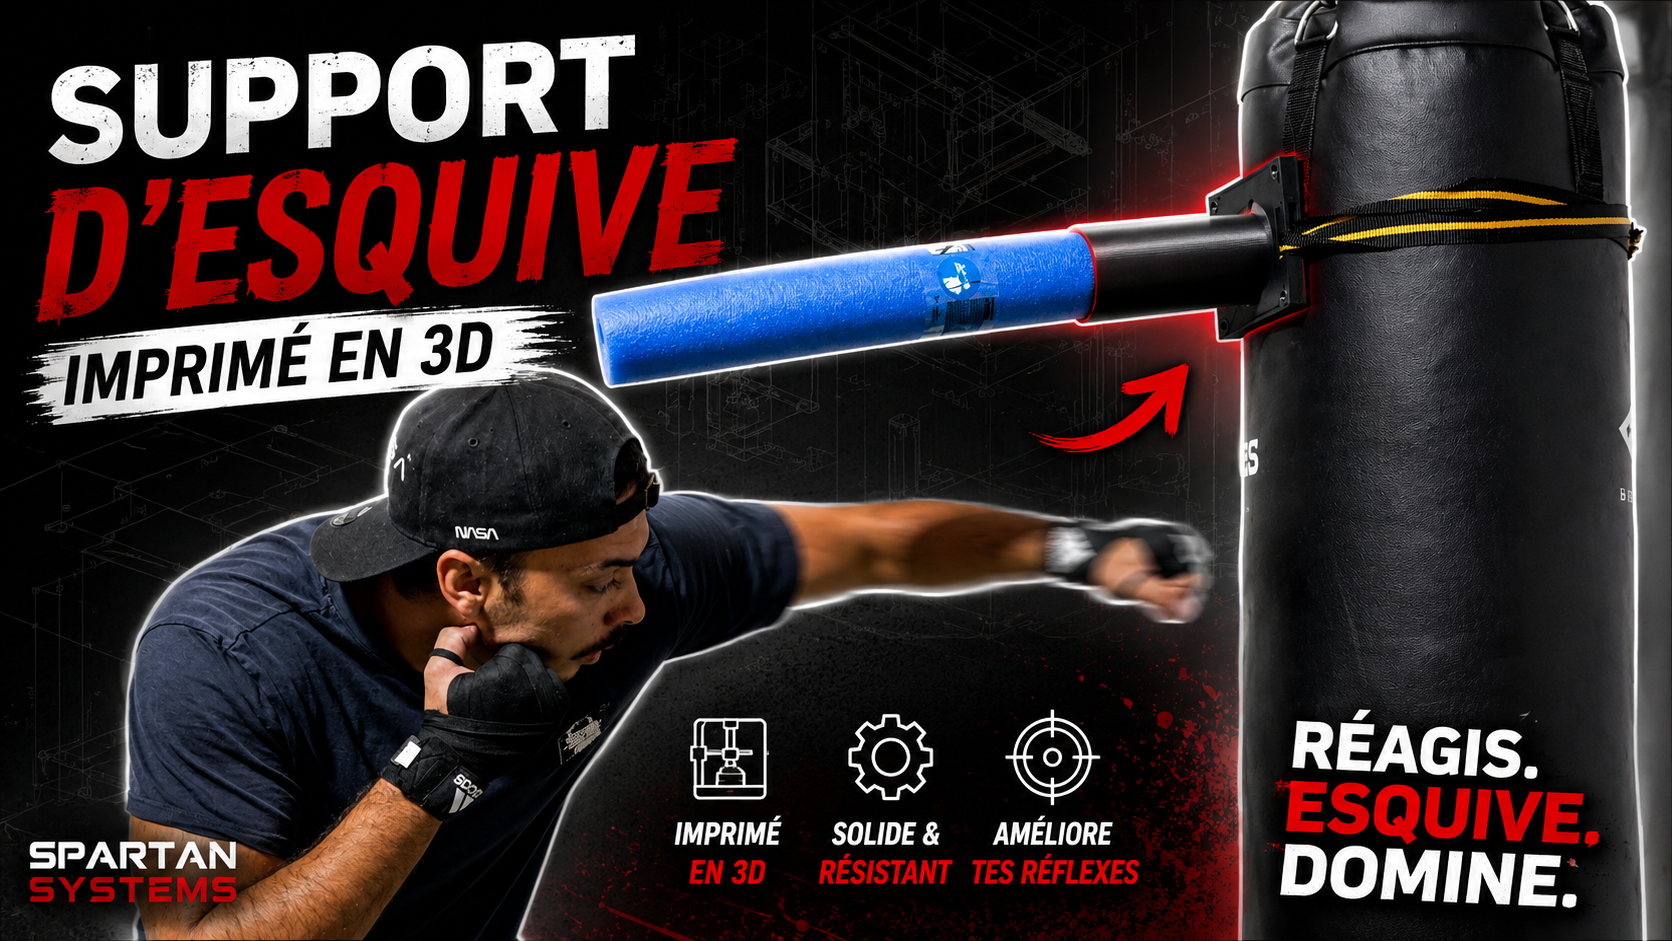
Designed in Fusion 360 and printed in PETG, Dodge v1 is a modular mount that turns a pool noodle into a boxing and MMA slip-and-dodge trainer — compact, cheap, and usable anywhere.
No marketing renders. No vapor specs. Spartan Systems starts from the real prototype: electronics, code, mechanics, networking, fabrication and field testing. We document the results as much as the mistakes that get us there.
Prototyping
Iteration cycle 03
Field Testing
Coastal sector
Soldering
PCB rev 1.4
Calibration
IMU offset